PIP robot mapping
Teaching a robot to map a room.
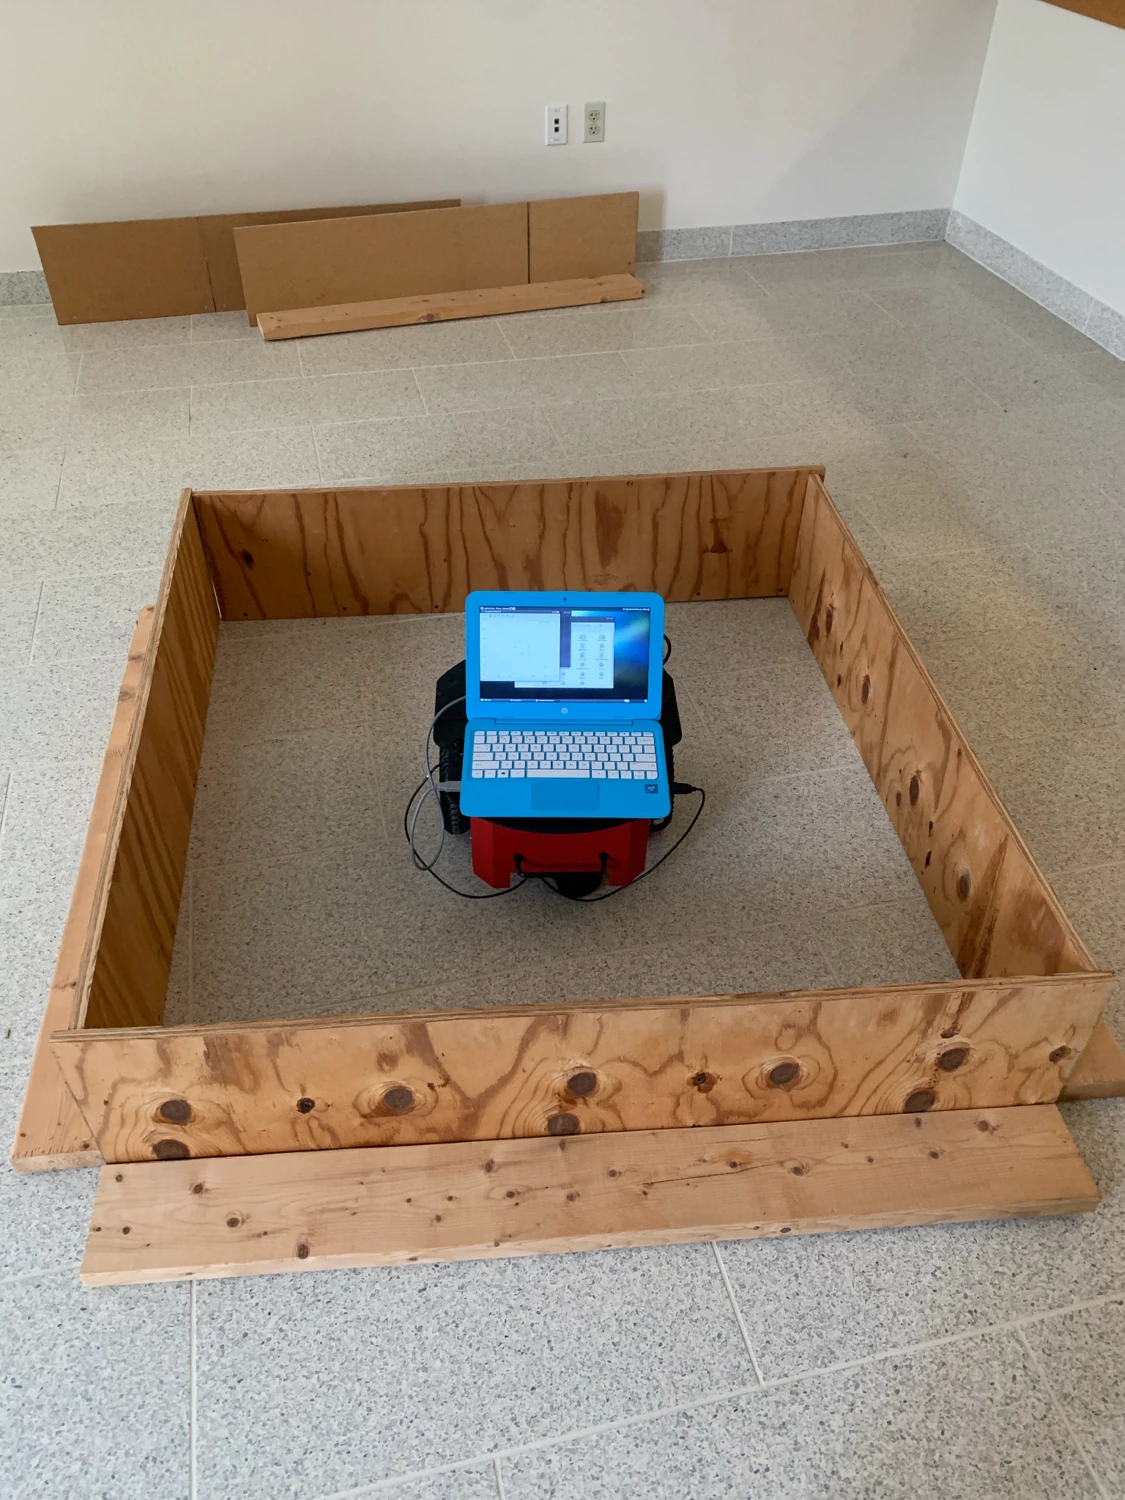
For my undergraduate capstone, I worked on mapping and navigation for PIP, a mobile robot, in C++, with Python for clustering and visualization.
A small wooden enclosure made a good test because its shape was known, so errors in the map were easy to see. Early sonar readings were noisy, especially in the corners. LiDAR gave a much cleaner outline.
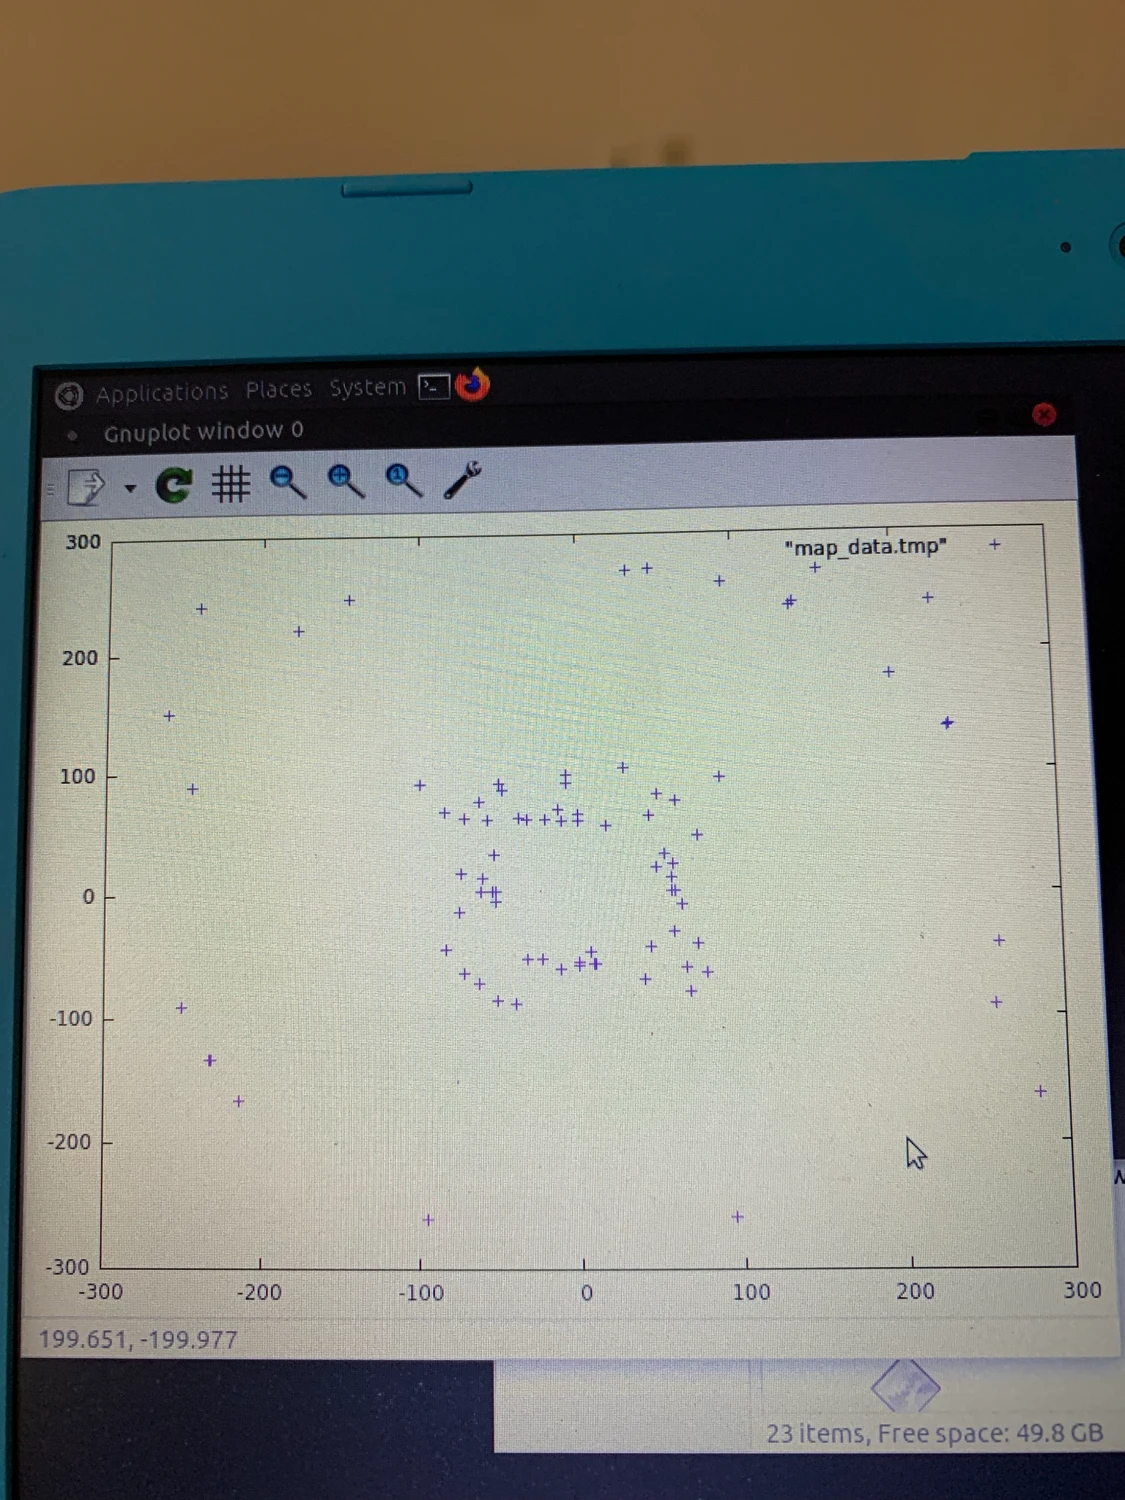
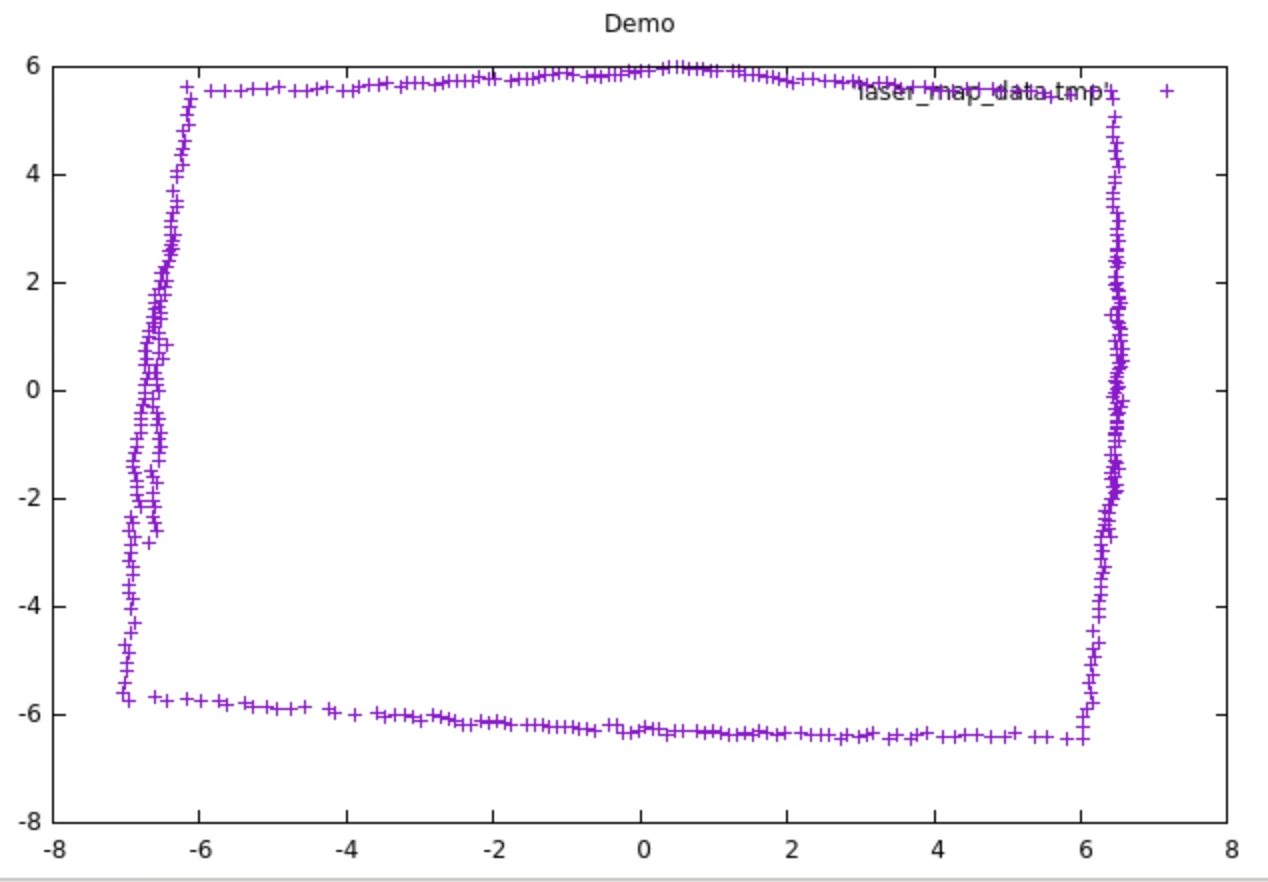
Turning distances into a map
Each reading is relative to the robot. Placing it on a shared map means transforming distance and bearing using the robot’s estimated position and heading, and small errors there make a familiar room look strange.
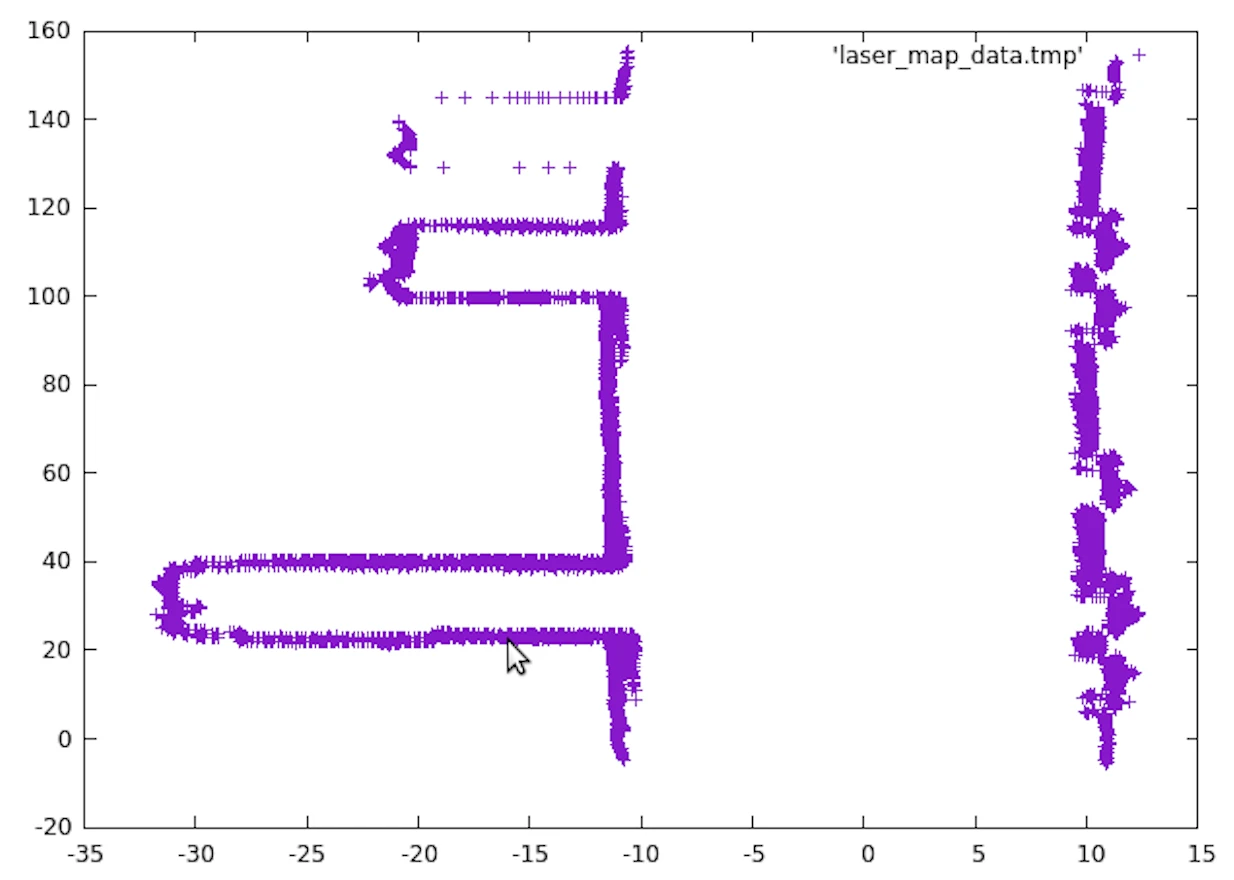
Loop closure and better localization were left as future work. Capstone project, 2022–2023.